
Raup’s model#
In this tutorial, you will use Raup’s model (Raup & Michelson, 1965; Raup, 1966) in both directions: generate coiled shells from parameters and estimate the parameters from a shell.
Raup’s model describes a shell as a trajectory of a generating curve, which mimics the aperture shape, that expands, rotates, and translates along a fixed coiling axis. Three parameters control the geometry:
whorl expansion rate
w_r: how fast the tube widens per revolutiontranslation rate
t_r: how fast the coil moves down along the coiling axisrelative distance of the generating curve from the coiling axis
d_r
Setup#
# Uncomment if needed
# %pip install "ktch[plot]"
import matplotlib.pyplot as plt
import numpy as np
import pandas as pd
import plotly.graph_objects as go
from plotly.subplots import make_subplots
from ktch.coiling import RaupModel
from ktch.plot import morphospace_plot
Generate your first shell#
RaupModel provides the model. Its inverse_transform takes the parameters
and returns a sampled surface.
We also pass a sampling grid (theta_range along the growth trajectory, phi_range around
the aperture).
theta = np.linspace(0.0, 2.0 * np.pi * 4.0, 240) # four whorls
phi = np.linspace(0.0, 2.0 * np.pi, 60)
raup_model = RaupModel()
X = raup_model.inverse_transform([1.3, 1.5, 0.2], theta_range=theta, phi_range=phi)
X.shape
(240, 60, 3)
You should see a (n_theta, n_phi, 3) array: n_theta samples along the coil,
n_phi samples around the tube, and the last axis holds the (x, y, z)
coordinates of each surface point.
Visualize in 3D#
Let’s define a small helper that turns a surface array into an interactive plotly figure.
fig = plot_surface3d(X, title="Raup's model (w_r=1.3, t_r=1.5, d_r=0.2)")
fig.show()
That’s a coiled shell built from three parameters.
Note
Raup’s model coils along the coiling axis (+z), so the apex sits at the bottom
of the raw output. plot_surface3d shows shells apex-up by default
(apex_up=True): it rotates the form 180° about a horizontal axis (a rotation,
not a z-flip, so the coiling direction is preserved). Pass apex_up=False for
the raw orientation.
Orientation of the aperture#
The full parameter vector of RaupModel has five entries. Ask the model for
their names:
raup_model.get_feature_names_out()
array(['w_r', 't_r', 'd_r', 'delta_r', 'gamma_r'], dtype='<U7')
The last two, delta_r and gamma_r, set the orientation of the aperture
(Noshita, 2014). With (0, 0) the aperture lies in the radial-axial plane, as
in the classical model; delta_r tilts it about the radial direction and
gamma_r turns it about the coiling axis. A 3-entry input, as above, sets both
to zero.
To compare several shells at once, we use a second helper that lays out a batch of surfaces in a grid of subplots.
Passing a (n_samples, 5) array to inverse_transform generates one surface
per row, so a comparison is a single call:
params = np.array(
[
[1.3, 1.5, 0.2, 0.0, 0.0],
[1.3, 1.5, 0.2, 0.4, 0.0],
[1.3, 1.5, 0.2, 0.0, 0.4],
]
)
surfaces = raup_model.inverse_transform(params, theta_range=theta, phi_range=phi)
surfaces.shape
(3, 240, 60, 3)
plot_surface_grid(
surfaces,
["delta_r=0, gamma_r=0", "delta_r=0.4, gamma_r=0", "delta_r=0, gamma_r=0.4"],
title="Orientation of the aperture",
).show()
The leading axis indexes the parameter rows; the rest is the familiar
(n_theta, n_phi, 3) surface.
Explore the parameters#
We vary one parameter while holding the other two constant to see each effect.
Whorl expansion rate w_r#
params = np.array([[1.1, 1.0, 0.0], [2.0, 1.0, 0.0], [10.0, 1.0, 0.0]])
plot_surface_grid(
raup_model.inverse_transform(params, theta_range=theta, phi_range=phi),
["w_r=1.1", "w_r=2.0", "w_r=10.0"],
title="Whorl expansion rate",
).show()
Translation rate t_r#
With t_r = 0 the whorls stay in a single plane (a planispiral); increasing it
stacks the whorls into a high-spired form.
params = np.array([[2.0, 0.0, 0.0], [2.0, 1.0, 0.0], [2.0, 4.0, 0.0]])
plot_surface_grid(
raup_model.inverse_transform(params, theta_range=theta, phi_range=phi),
["t_r=0.0", "t_r=1.0", "t_r=4.0"],
title="Translation rate",
).show()
Relative distance from the coiling axis d_r#
d_r (in (-1, 1)) sets how far the generating curve sits from the coiling
axis.
params = np.array([[2.0, 1.0, -0.4], [2.0, 1.0, 0.0], [2.0, 1.0, 0.4]])
plot_surface_grid(
raup_model.inverse_transform(params, theta_range=theta, phi_range=phi),
["d_r=-0.4", "d_r=0.0", "d_r=0.4"],
title="Distance from the axis",
).show()
Estimate the parameters#
Now, the reverse direction. transform takes a shell surface and estimates the
parameters from it. The "surface" method fits the model directly
to a structured surface.
Note
The default estimator="ml_2d" expects lateral and umbilical measurements of a
specimen, the conventional measurements of Raup’s model, and is not covered here.
We generate a shell with a known parameter vector, including the orientation, and then try to estimate it.
params_true = np.array([1.3, 1.5, 0.2, 0.3, -0.2])
X = raup_model.inverse_transform(params_true, theta_range=theta, phi_range=phi)
raup_model.set_params(estimator="surface")
params_est = raup_model.transform(X)
params_est.shape
(1, 5)
set_params selects the estimation method; inverse_transform is not
affected. transform works on a panel of surfaces. The result has one row
per surface. A single (n_theta, n_phi, 3) array is accepted as a panel of one.
pd.DataFrame(
{"true": params_true, "estimated": params_est[0]},
index=raup_model.get_feature_names_out(),
)
| true | estimated | |
|---|---|---|
| w_r | 1.3 | 1.3 |
| t_r | 1.5 | 1.5 |
| d_r | 0.2 | 0.2 |
| delta_r | 0.3 | 0.3 |
| gamma_r | -0.2 | -0.2 |
You should see the five parameters recovered to numerical precision. The
"surface" method fits the rigid pose and the scale of the surface together
with the parameters. It does not require the shell to sit in any particular
position or orientation.
To close the loop, generate a shell from the estimate and compare it with the original:
X_rec = raup_model.inverse_transform(params_est[0], theta_range=theta, phi_range=phi)
rmsd = np.sqrt(np.mean(np.sum((X_rec - X) ** 2, axis=-1)))
print(f"root-mean-square distance: {rmsd:.2e}")
root-mean-square distance: 2.58e-16
X_up = X * np.array([-1.0, 1.0, -1.0]) # apex-up, as in plot_surface3d
X_rec_up = X_rec * np.array([-1.0, 1.0, -1.0])
fig = go.Figure(
data=[
go.Surface(
x=X_up[..., 0], y=X_up[..., 1], z=X_up[..., 2],
colorscale="Viridis", opacity=0.8, showscale=False,
),
go.Surface(
x=X_rec_up[..., 0], y=X_rec_up[..., 1], z=X_rec_up[..., 2],
colorscale="Reds", opacity=0.4, showscale=False,
),
]
)
fig.update_layout(
title="Original (Viridis) and reconstruction (Reds)",
width=700,
height=500,
scene=dict(aspectmode="data"),
)
fig.show()
The two surfaces coincide. This is the sense in which transform and
inverse_transform are inverses of each other: a parameter vector, the shell it
generates, and the parameters estimated from that shell describe the same form.
Note
The "surface" method assumes that rows run along the coil and columns run
once around the tube, as in the output of inverse_transform. It uses the
coordinates only: the grid values theta_range and phi_range are not needed.
Many shells at once#
Both directions work on batches. A (n_samples, 5) parameter array gives a
(n_samples, n_theta, n_phi, 3) panel, and transform on that panel gives the
parameters back row by row.
params_batch = np.array(
[
[1.2, 0.5, 0.1, 0.0, 0.0],
[1.5, 1.5, 0.2, 0.2, 0.1],
[2.0, 0.0, 0.05, -0.1, 0.3],
]
)
surfaces = raup_model.inverse_transform(params_batch, theta_range=theta, phi_range=phi)
estimates = raup_model.transform(surfaces)
pd.DataFrame(estimates, columns=raup_model.get_feature_names_out())
| w_r | t_r | d_r | delta_r | gamma_r | |
|---|---|---|---|---|---|
| 0 | 1.2 | 5.000000e-01 | 0.10 | 4.281314e-19 | 2.258123e-18 |
| 1 | 1.5 | 1.500000e+00 | 0.20 | 2.000000e-01 | 1.000000e-01 |
| 2 | 2.0 | 7.999309e-18 | 0.05 | -1.000000e-01 | 3.000000e-01 |
print(f"largest absolute error: {np.max(np.abs(estimates - params_batch)):.2e}")
largest absolute error: 1.33e-15
For analysis pipelines, pass as_frame=True to get a tidy long-format
DataFrame indexed by (specimen_id, trajectory_id, phi_id). transform
accepts this frame as well.
df = raup_model.inverse_transform(
params_batch, theta_range=theta, phi_range=phi, as_frame=True
)
df.head()
| x | y | z | |||
|---|---|---|---|---|---|
| specimen_id | trajectory_id | phi_id | |||
| 0 | 0 | 0 | 2.222222 | 0.0 | 1.111111 |
| 1 | 2.216557 | 0.0 | 1.217405 | ||
| 2 | 2.199626 | 0.0 | 1.322494 | ||
| 3 | 2.171620 | 0.0 | 1.425188 | ||
| 4 | 2.132857 | 0.0 | 1.524323 |
Morphospace#
A theoretical morphospace is the parameter space viewed through the shells it
generates. morphospace_plot from ktch.plot draws a scatter plot in a
two-dimensional space and places generated shapes at a regular grid of
positions. It expects a reducer (such as PCA) between the axes and the
descriptor; here the axes are the parameters w_r and t_r themselves, so
the reducer is the identity, and the descriptor is inverse_transform with
d_r fixed.
d_fixed = 0.1
def shells_at(w_t):
"""Generate one shell per ``(w_r, t_r)`` row at ``d_r = d_fixed``, apex-up."""
w_t = np.asarray(w_t)
params = np.column_stack([w_t, np.full(len(w_t), d_fixed)])
X = raup_model.inverse_transform(
params,
theta_range=np.linspace(0.0, 2.0 * np.pi * 4.0, 120),
phi_range=np.linspace(0.0, 2.0 * np.pi, 30),
)
return X * np.array([-1.0, 1.0, -1.0]) # apex-up, as in plot_surface3d
fig, ax = plt.subplots(figsize=(7, 6))
ax.set_xlim(1.1, 4.5)
ax.set_ylim(-0.5, 3.5)
morphospace_plot(
reducer_inverse_transform=lambda scores: scores, # axes are the parameters
n_components=2,
descriptor_inverse_transform=shells_at,
n_shapes=3,
shape_scale=0.9,
ax=ax,
)
ax.scatter(estimates[:, 0], estimates[:, 1], zorder=2)
for i, (w, t) in enumerate(estimates[:, :2]):
ax.annotate(f"shell {i}", (w, t), xytext=(5, 5), textcoords="offset points")
ax.set_xlabel("w_r (whorl expansion rate)")
ax.set_ylabel("t_r (translation rate)")
ax.set_title("Morphospace over w_r and t_r (d_r=0.1)");
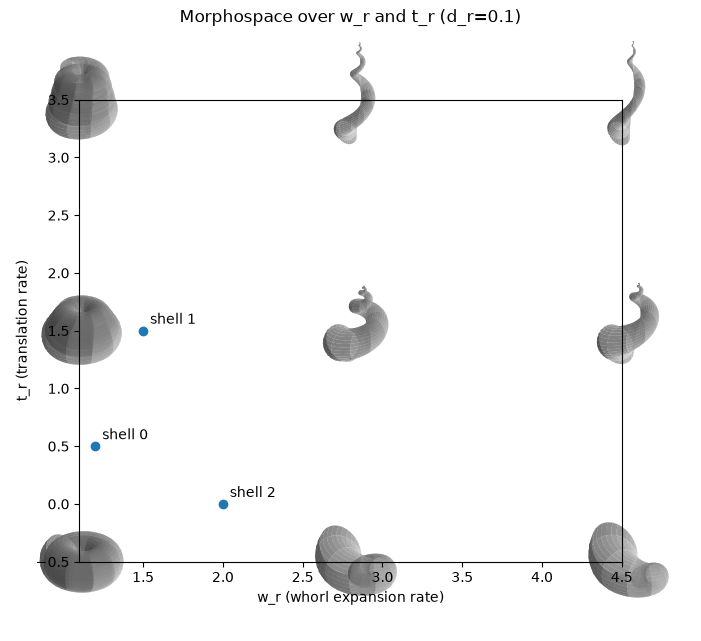
The insets show the shells generated at the grid positions; the points are the shells estimated in the previous section. Generation places a shell at a point of the morphospace; estimation reads the point back from the shell. Use the first to design shells and the second to locate specimens.
See also
Growing tube model to do the same with the growing tube model, including heteromorph (non-constant) growth.
Sample evenly along a coiled shell to space the samples evenly along the shell instead of evenly in
theta.Theoretical morphological models of coiling for the theory behind Raup’s model.
References#
Noshita, K., 2014. Quantification and geometric analysis of coiling patterns in gastropod shells based on 3D and 2D image data. Journal of Theoretical Biology 363, 93–104.
Raup, D.M., Michelson, A., 1965. Theoretical Morphology of the Coiled Shell. Science 147, 1294–1295.
Raup, D.M., 1966. Geometric analysis of shell coiling: general problems. Journal of Paleontology 40, 1178–1190.